tweetindex
ES

Generalist ✓

@GeneralistAI · joined 07 Jun 2025

Generalist is an AI robotics company building general intelligence for the physical world and making it useful to everyone.

25 079Followers
23Following
189Posts total
5.9MViews on collected posts

Últimas publicaciones

A simple example of physical prompt steerability: same environment, different prompts, different behaviors. Thanks @JagdeepBhatia8 for the suggestion. Read more about GEN-1.5 in our blog post in the comments below. https://t.co/IuJFiye3FW 18K views · 108 likes · 10 reposts · 6 replies Open on X →
We've reduced the time it takes to go from physical prompt → robot behavior. The faster anyone can teach a robot to do something new, the easier it becomes to scale physical work. Read more about GEN-1.5 in our blog post in the comments below. https://t.co/8YjpRF2imw 25.2K views · 235 likes · 27 reposts · 8 replies Open on X →
Physical prompting is an elegant idea! One request for the @GeneralistAI team: can we see an example of *physical prompt steerability*, where different prompts induce distinct behavior in the *same* environment? I'm curious whether GEN-1.5 is listening to the physical prompt or 17.6K views · 36 likes · 0 reposts · 2 replies Open on X →
@GeneralistAI GPT3! 29.8K views · 354 likes · 17 reposts · 6 replies Open on X →
GEN-1.5 has been training continuously for over 8 months. We left it running because every metric we tracked kept improving with the engine: absorbing more data, scaling more efficiently, boosting post-training, and compounding step-change improvements through algorithmic https:/
56.6K views · 327 likes · 15 reposts · 4 replies Open on X →
To us, GEN-1.5 represents a new frontier of generality — one that challenges our own understanding of how these models behave when pretrained at a scale of physical interaction data few thought possible without shortcuts. We do not yet see where this asymptotes. Read more in the 41.6K views · 306 likes · 20 reposts · 3 replies Open on X →
The model sometimes uses both hands to rotate a jar lid, with a fundamentally different contact and motion strategy than the fine-tuning demonstrations. https://t.co/bHujggVt9f
0:06
18.6K views · 162 likes · 2 reposts · 1 replies Open on X →
Here’s an uncut video of prompting the model to perform 2 different tasks back-to-back: (i) unzipping a pencil pouch, and (ii) retrieving money from the pouch. https://t.co/LVKN8qXDwJ
0:50
20.1K views · 160 likes · 5 reposts · 2 replies Open on X →
Or when fine-tuned to place a block into a bowl, it can clear obstacles (like a piece of paper covering the bowl) to complete the task, despite that not being in the demonstrations. https://t.co/jbcdrI2CTv
0:23
73.8K views · 186 likes · 4 reposts · 1 replies Open on X →
Fine-tuned (or prompted) behaviors generalize beyond their demonstrations, and can improvise fundamentally different manipulation strategies to achieve the same goal. For example, after fine-tuning to use a brush to sweep a block into a bowl, it could use other tools like a http
0:13
23.4K views · 183 likes · 3 reposts · 1 replies Open on X →
When a Lego brick gets unexpectedly stuck on the fingertips, the model uses the other hand to remove them. https://t.co/HhonSf39KI
0:10
20.8K views · 233 likes · 9 reposts · 2 replies Open on X →
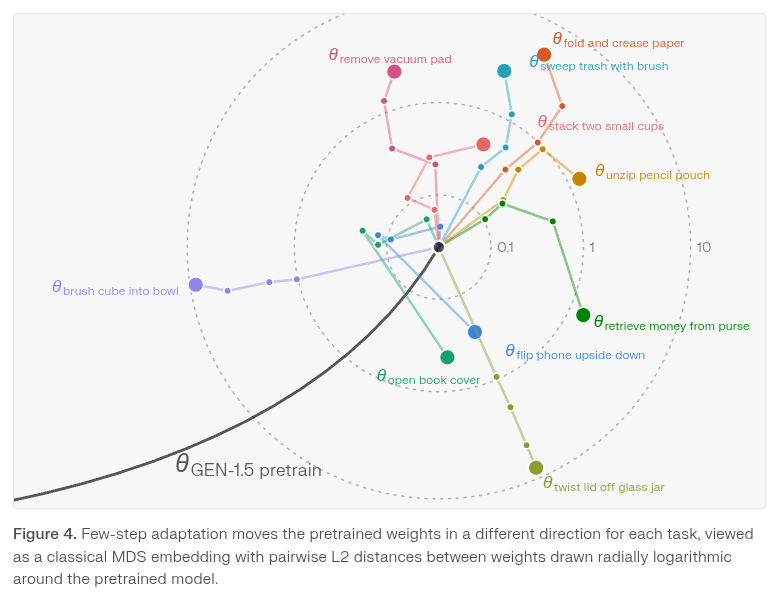
For few-shot learning, it can adapt to new physical tasks in as few as 1 - 10 gradient steps on 1 - 5 minutes of data (~10 - 50 demonstrations). In practice, this can be described as test-time training in a low-data regime. We did not tune this procedure or sweep hyperparameters;
79.4K views · 365 likes · 15 reposts · 1 replies Open on X →
Experiments across 10 diverse tasks show 59% average success with one-shot physical prompting, straight from pretraining. With few-shot learning, performance rises to 83% via 10 gradient steps on 5 minutes of data per task. Although the tasks are simple and success rates are htt
0:13
45.8K views · 214 likes · 7 reposts · 1 replies Open on X →
In-context learning also crosses the sim-to-real gap, zero-shot. Prompts can be formed entirely from simulated experience (e.g., from a scripted policy, an RL agent, or a human teleoperating a simulated robot) and be used to produce behaviors on a real robot. The model was not ht
0:30
62.6K views · 313 likes · 13 reposts · 3 replies Open on X →
In some cases, in-context learning with GEN-1.5 transfers across the embodiment gap entirely: a human demonstrates a task with their own hands, observable through the robot’s cameras, and the robot can reproduce it immediately afterward. https://t.co/wdcEDABDyf
0:30
54.4K views · 368 likes · 19 reposts · 5 replies Open on X →
Physical prompts can be composed. Demonstrations of 2 different tasks in context prompts GEN-1.5 to chain them into one continuous skill. The model bridges them and produces intermediate motions (repositioning, regrasping, error recovery) that appear in neither demonstration. htt
0:26
55.5K views · 352 likes · 12 reposts · 1 replies Open on X →
GEN-1.5, our latest embodied foundation model, can learn new tasks prompted with 3 - 12 seconds of a single demonstration, no gradient updates or fine-tuning. It generalizes prompts to new situations, recovers from mistakes, and improvises new strategies to reach the same goal. h
0:23
136.8K views · 792 likes · 39 reposts · 7 replies Open on X →
Introducing GEN-1.5, a one-shot learner. It can learn new tasks in a few seconds. Show it what to do, and it generalizes. This capability emerged from pretraining on physical data at scale, as a step towards our mission of building general intelligence for the physical world. h
3:32
3.4M views · 12.2K likes · 1.7K reposts · 318 replies Open on X →
@GeneralistAI Great work! We have a low-cost, 3D-printed quick-swapping system build on a 1 DoF gripper that generalizes across everyday tools https://t.co/gsgWYhWV3Y We can even attach it to a $7 hand :) https://t.co/xOXYSOBUVO 968 views · 13 likes · 1 reposts · 0 replies Open on X →
If we can build general intelligence that understands the underlying physics of interaction, then the shape of the hand becomes secondary to the intelligence that drives it. A suction pad, a gripper, a brush, a plasma welding nozzle – are all just different interfaces through 7.5K views · 69 likes · 5 reposts · 0 replies Open on X →
Nature didn’t converge on just a single solution for manipulating the physical world. It exploded into millions. You can see this everywhere in the diversity of life around us: from the beak of a bird, to the trunk of an elephant, from the suction pads of an octopus, to the https 5K views · 42 likes · 3 reposts · 2 replies Open on X →
What happens when you change the hand mid-task? We tested this by modifying the hands mid-rollout and letting the same model keep running. It perceives the new tool, and finds a new trajectory and contact strategy to complete the task. This works because training on mixed data h 22K views · 93 likes · 9 reposts · 1 replies Open on X →
Unlike humans, robots aren’t locked into the hands they’re born with. Machines can easily swap mechanical hands, and tool changers are common in automation. Switching between different end effectors to reach a goal can be viewed as a form of physical reasoning: using the right ht 3.3K views · 46 likes · 0 reposts · 1 replies Open on X →
Every hand is a different language for physical interaction. Just as training on multiple languages produces more capable LLMs, a model trained across embodiments can gather shared knowledge across instances and more readily separate what is specific to a hand from what is https: 4.4K views · 72 likes · 1 reposts · 1 replies Open on X →
Each hand is a different sensorimotor interface by which GEN-1 experiences the physical world. Scaling pretraining across thousands of these interfaces teaches GEN-1 a universal physical commonsense that transfers to new hands and new ways to grasp, push, pull, twist, and more. h 31.6K views · 114 likes · 6 reposts · 1 replies Open on X →
Why create robot intelligence for just one hand, when we could have it learn from many? GEN-1, our latest embodied foundation model, now supports a broad range of end effectors from 5-finger hands, to specialized tools, and everything in between. https://t.co/ECKlXvARdx 299.6K views · 918 likes · 109 reposts · 34 replies Open on X →
We are also hiring on many fronts across research, technical infrastructure, partnerships, and several others. We are incredibly proud of our team. If you'd like to chat about joining, let us know! https://t.co/RbXLdGNIBw https://t.co/Abe51Q91QB 54.8K views · 67 likes · 4 reposts · 6 replies Open on X →
@GeneralistAI dang. you hiring? I have been developing simulators & simulator renders to train RL policies from pixels. I can train a generalist drone policy that transfers to the real world using pixels as obs in under 2 minutes 33.7K views · 459 likes · 1 reposts · 22 replies Open on X →
You can read more about what this means and where we’re headed here “https://t.co/ndiPL0Llbz” 9.7K views · 41 likes · 1 reposts · 1 replies Open on X →
New major investors include Radical Ventures (lead), 8VC, Union Square Ventures, Hanabi Capital, Norwest and all our major existing investors participated significantly including NVIDIA's NVentures, Boldstart Ventures, Spark Capital, Bezos Expeditions, and NFDG. New angel 5.6K views · 49 likes · 0 reposts · 3 replies Open on X →

Frente a cuentas del mismo tamaño

18 publicaciones de los últimos 90 días, junto al rango de 10K–100K seguidores. llega a mucha gente, pero pocos de esos espectadores reaccionan.

Visualizaciones medianas43 701esta cuenta924mediana de 10K–100K
Alcance, %174.25%esta cuenta3.62%mediana de 10K–100K
Interacción, %0.69%esta cuenta1.52%mediana de 10K–100K
MétricaEsta cuentaMediana de 10K–100KProporción
Visualizaciones medianas por publicación43 70192447.3×
Alcance (visualizaciones ÷ seguidores)174.25%3.62%48.1×
Tasa de interacción0.69%1.52%0.45×

Otras cuentas de este rango →   Comparar con otra cuenta →   Cómo se construyen estas referencias →

Growth & engagement

How the posts we collected actually performed: views and reaction rate post by post, what the audience did with them, and where the follower count goes.

Views per post

62.6K19 Aug
45.8K
79.4K
20.8K
23.4K
73.8K
20.1K
18.6K
41.6K
56.6K
29.8K
17.6K21 Aug
25.2K24 Aug
18K26 Aug

Last 14 collected posts, oldest on the left. The scale is logarithmic: one post can outrun the rest a hundred times over.

Engagement rate per post

0.53%19 Aug
0.49%
0.49%
1.20%
0.80%
0.26%
0.84%
0.89%
0.81%
0.63%
1.28%
0.23%21 Aug
1.08%24 Aug
0.71%26 Aug

Reactions — likes, reposts, replies and quotes — divided by views. Median for 10K–100K accounts is 1.52%.

What the audience does

Likes63.4%18 856 in total
Reposts6.9%2 051 in total
Replies1.5%444 in total
Quotes3.4%1 020 in total
Bookmarks24.8%7 358 in total

Share of every reaction we collected for this account. Replies mean argument, reposts mean endorsement, bookmarks mean the post was worth keeping.

The follower curve appears once this account has two daily snapshots — we take one a day, and this one is on its first.

Cuentas similares